Basic Aerodynamics
How Drones Fly
Understanding basic aerodynamics isn’t just exam material. It helps you fly better and troubleshoot problems. The FAA tests 7-11% of the exam on loading and performance topics.
The Four Forces of Flight
Every aircraft, including drones, is subject to four forces:
- Lift: upward force created by propellers/rotors spinning through air
- Weight: downward force of gravity pulling the drone toward earth
- Thrust: forward force created by the propellers pushing air
- Drag: backward force resisting motion through the air
In Steady Flight
- Lift = Weight (drone stays at constant altitude)
- Thrust = Drag (drone maintains constant speed)
When lift exceeds weight, the drone climbs. When weight exceeds lift, it descends.
The FAA asks about these force relationships. In steady, level flight, opposing forces are equal. Any imbalance causes a change in altitude or speed.
Angle of Attack
Angle of Attack (AoA) is the angle between the propeller blade (chord line) and the relative wind (oncoming air).
- Increasing AoA = more lift (up to a point)
- Decreasing AoA = less lift
- Critical AoA: the angle where the airflow separates from the blade surface, causing a stall
Stalls
A stall occurs when the angle of attack exceeds the critical angle:
- Air can no longer flow smoothly over the propeller blade
- Lift is lost dramatically
- Recovery requires reducing the angle of attack
Drones can stall their propellers in aggressive maneuvers or in turbulent air. The flight controller usually compensates automatically, but understanding stalls helps explain unexpected behavior.
Ground Effect
When a drone (or helicopter) hovers close to the ground (within about one rotor diameter), the ground interrupts the downward airflow:
- Less induced drag: the air cushion reduces the work the propellers need to do
- More efficient: requires less power to maintain hover
- Can cause issues on landing: the drone may “float” and resist settling down
Ground effect occurs within approximately one rotor diameter of the surface. It makes hovering more efficient but can make precise landing tricky.
Load Factor
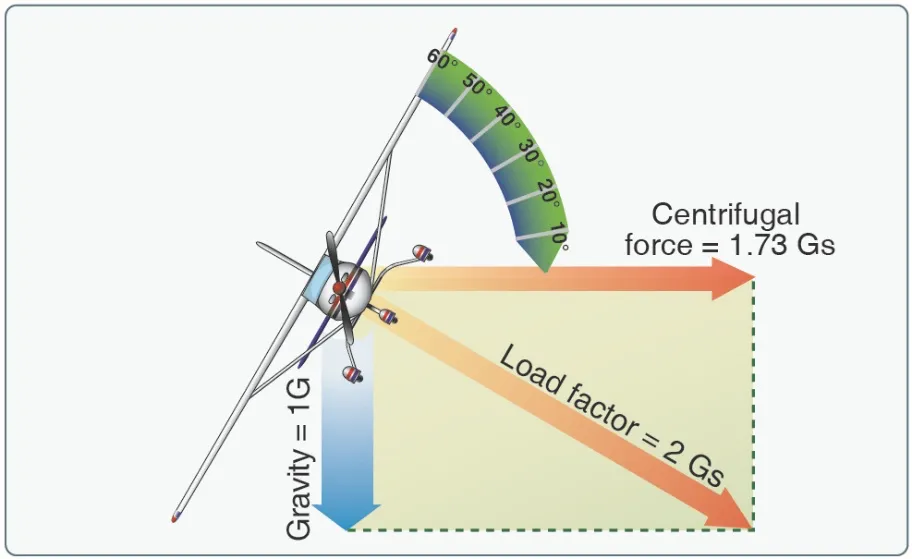
Load factor is the ratio of lift to weight. In level flight, load factor = 1G.
During turns, load factor increases:
- 30 degree bank = ~1.2G
- 45 degree bank = ~1.4G
- 60 degree bank = 2.0G
- 80 degree bank = ~5.8G
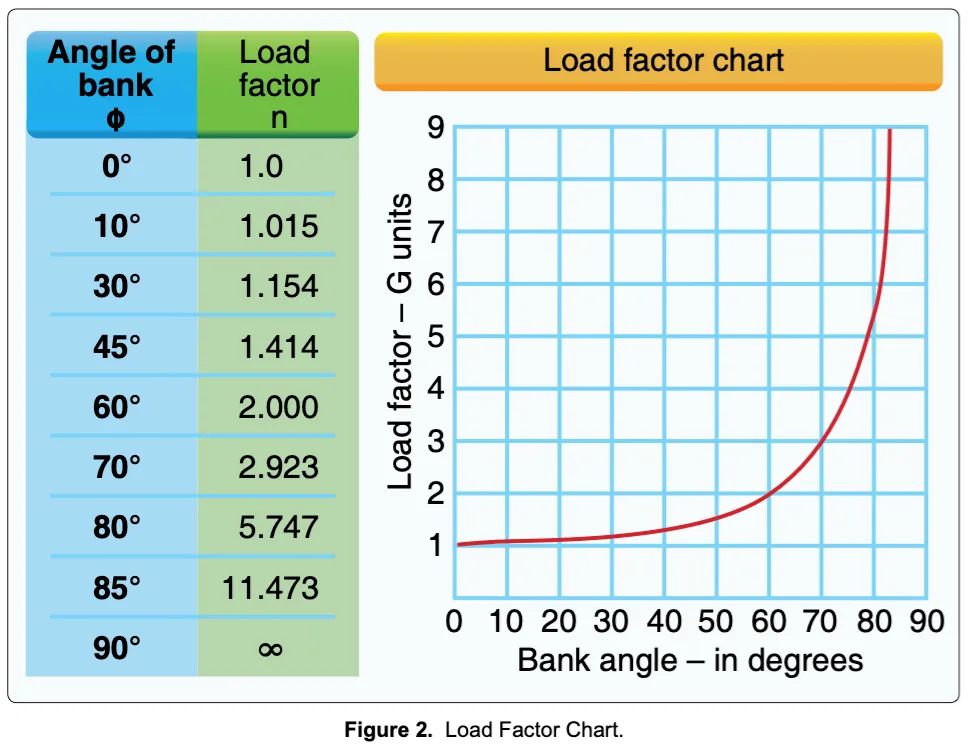
Higher load factor means:
- More stress on the airframe
- Higher stall speed
- Reduced performance margin
Stall Speed Follows the Square Root
Load factor and stall speed are locked together: stall speed increases with the square root of the load factor. At 60° bank, where load factor doubles (2.0 G), stall speed rises by √2 ≈ 1.41 — a 41% increase. An aircraft that stalls at 30 knots straight and level stalls near 42 knots in that 60-degree turn. The curve is cruel in the last 20 degrees of bank: from 60° to 80°, load factor climbs from 2.0 to about 5.8, and stall speed rises by roughly 2.4×.
Aggressive maneuvers increase load factor. Your drone’s flight controller limits bank angles to prevent exceeding structural limits — but the physics applies to camera moves too: a fast “whip pan” or a hard braking stop loads the props exactly the way a steep turn loads a wing, and a prop that stalls under load loses authority precisely when the maneuver needs it most.
Torque, P-Factor, and the Left-Turning Tendencies
Manned single-engine aircraft fight a set of “left-turning tendencies” the FAA expects you to recognize by name:
- Torque effect: the engine spins the propeller; the equal-and-opposite reaction tries to roll the aircraft the other way (the reason a conventional quad’s props alternate clockwise and counterclockwise — each pair cancels the other’s torque)
- P-factor (asymmetric propeller loading): at high angles of attack, the descending blade bites more air than the ascending blade, yawing the nose toward the descending side
- Slipstream spiraling and gyroscopic precession: the corkscrew of propwash and a pitching propeller’s gyroscopic reaction both add their own yaw inputs
Drone pilots meet the family in two places: on the exam (the manned questions) and in the air whenever a multirotor loses a motor — suddenly torque is unbalanced and the frame yaws toward the dead corner, which is why loss-of-one-motor behavior starts with an uncommanded spin.
Bernoulli’s Principle and Newton’s Laws
Two theories explain how propellers generate lift:
- Bernoulli’s Principle: Air moving faster over the curved top of a propeller blade creates lower pressure, producing an upward force
- Newton’s Third Law: Propellers push air downward, and the equal and opposite reaction pushes the drone upward
Both are correct and work together.
Quick Check
Q: What are the four forces of flight? A: Lift, Weight (gravity), Thrust, Drag.
Q: What causes a stall? A: Exceeding the critical angle of attack. The air separates from the blade or propeller surface.
Q: What is ground effect? A: Increased efficiency when hovering close to the ground (within one rotor diameter), caused by reduced induced drag.
What’s Next?
Now let’s look at how weight, balance, and loading affect your drone’s performance in real-world conditions.
This free course covers the essential knowledge, but if you want video walkthroughs, practice exams, and instructor support, Pilot Institute’s Part 107 course is the most comprehensive option available.